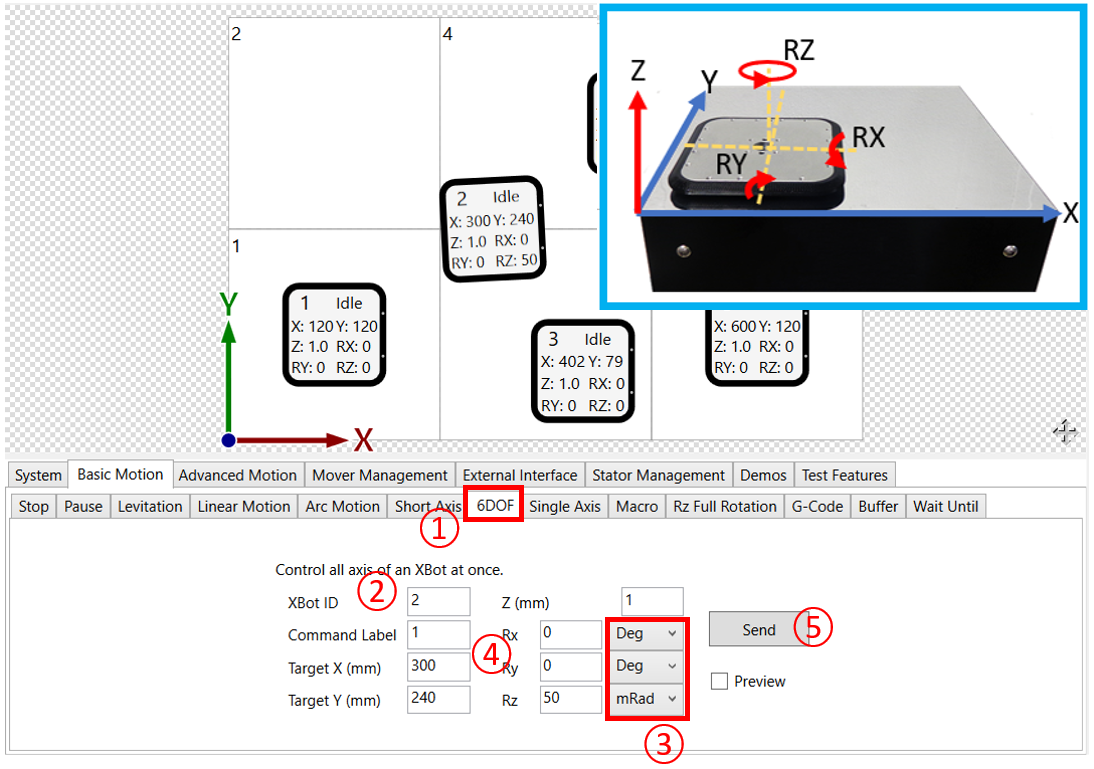
① Click the Basic Motion \ 6DOF tab
② Enter the XBot ID
③ Choose desired unit for rotation angles (mrad or degrees)
④ Enter target position (X, Y, Z, Rx, Ry, Rz)
⑤ Click Send when ready
Note:
-
While it is not possible to specify the speed in the Planar Motor Tool for the 6DOF command, it is possible to specify the speed in the programming libraries.